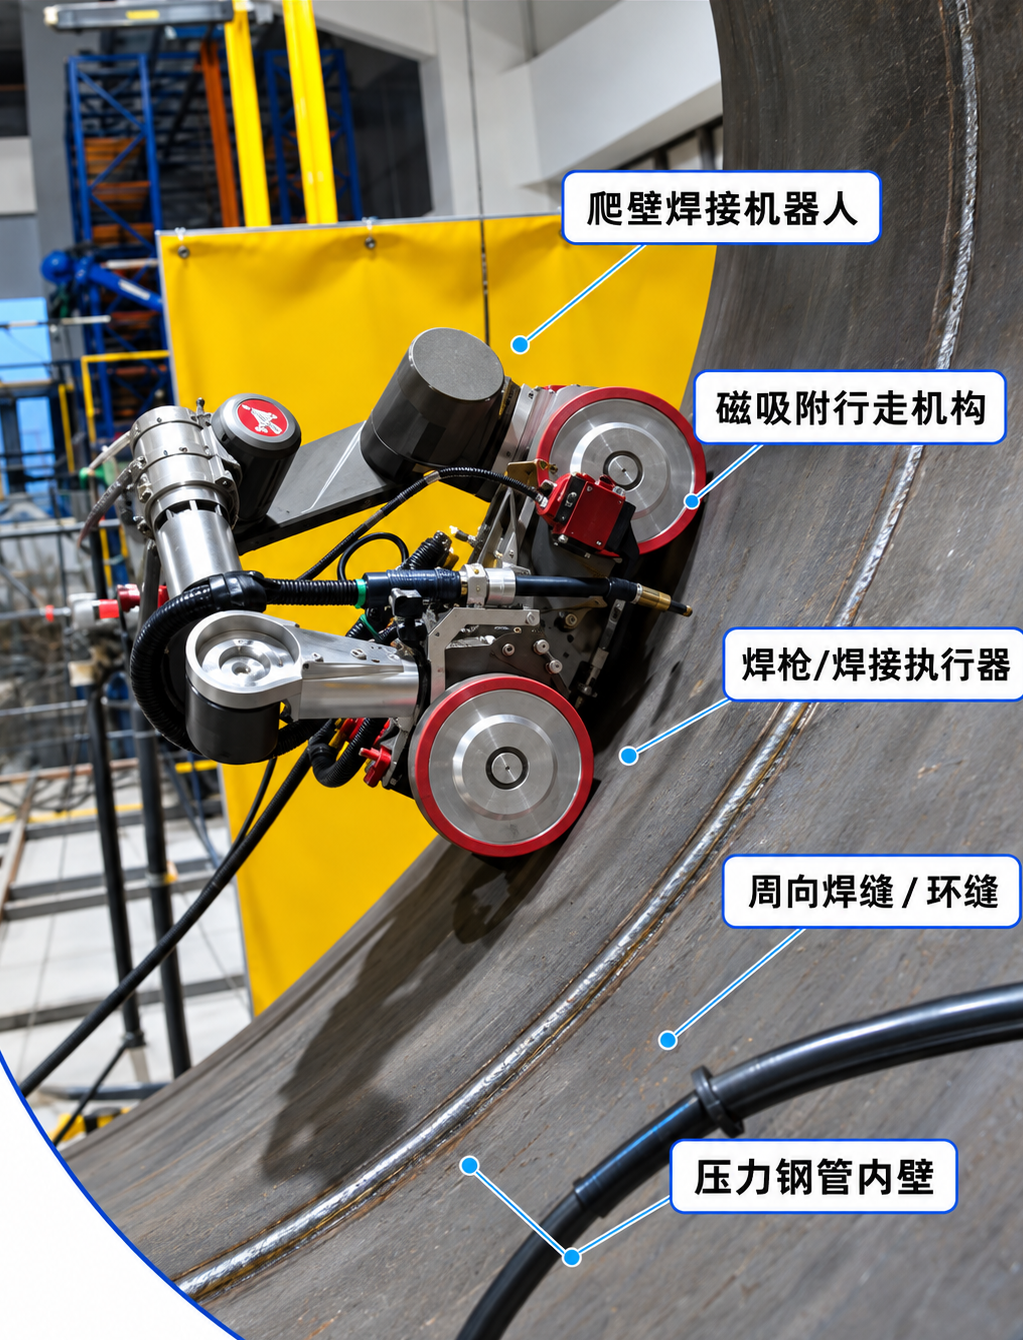
A magnetic mobile platform, manipulator and vision sensors support research on seam perception, path planning and welding control inside pressure pipes.
Prototype integration and laboratory work address pre-weld localization, seam identification and coordination of the mobile platform and manipulator. The vision-language workflow explores the route from task descriptions to welding trajectories.